Balance Bot

My journey building a 2-wheel bot.
Intended features:
- ability to keep balance when stationary and during movement forward/backward/left/right
- control with remote (radio controller or bluetooth gamepad)
- be able to run independently on a stadium track
- be able to follow someone (me) during running
Stack (at the time of writing):
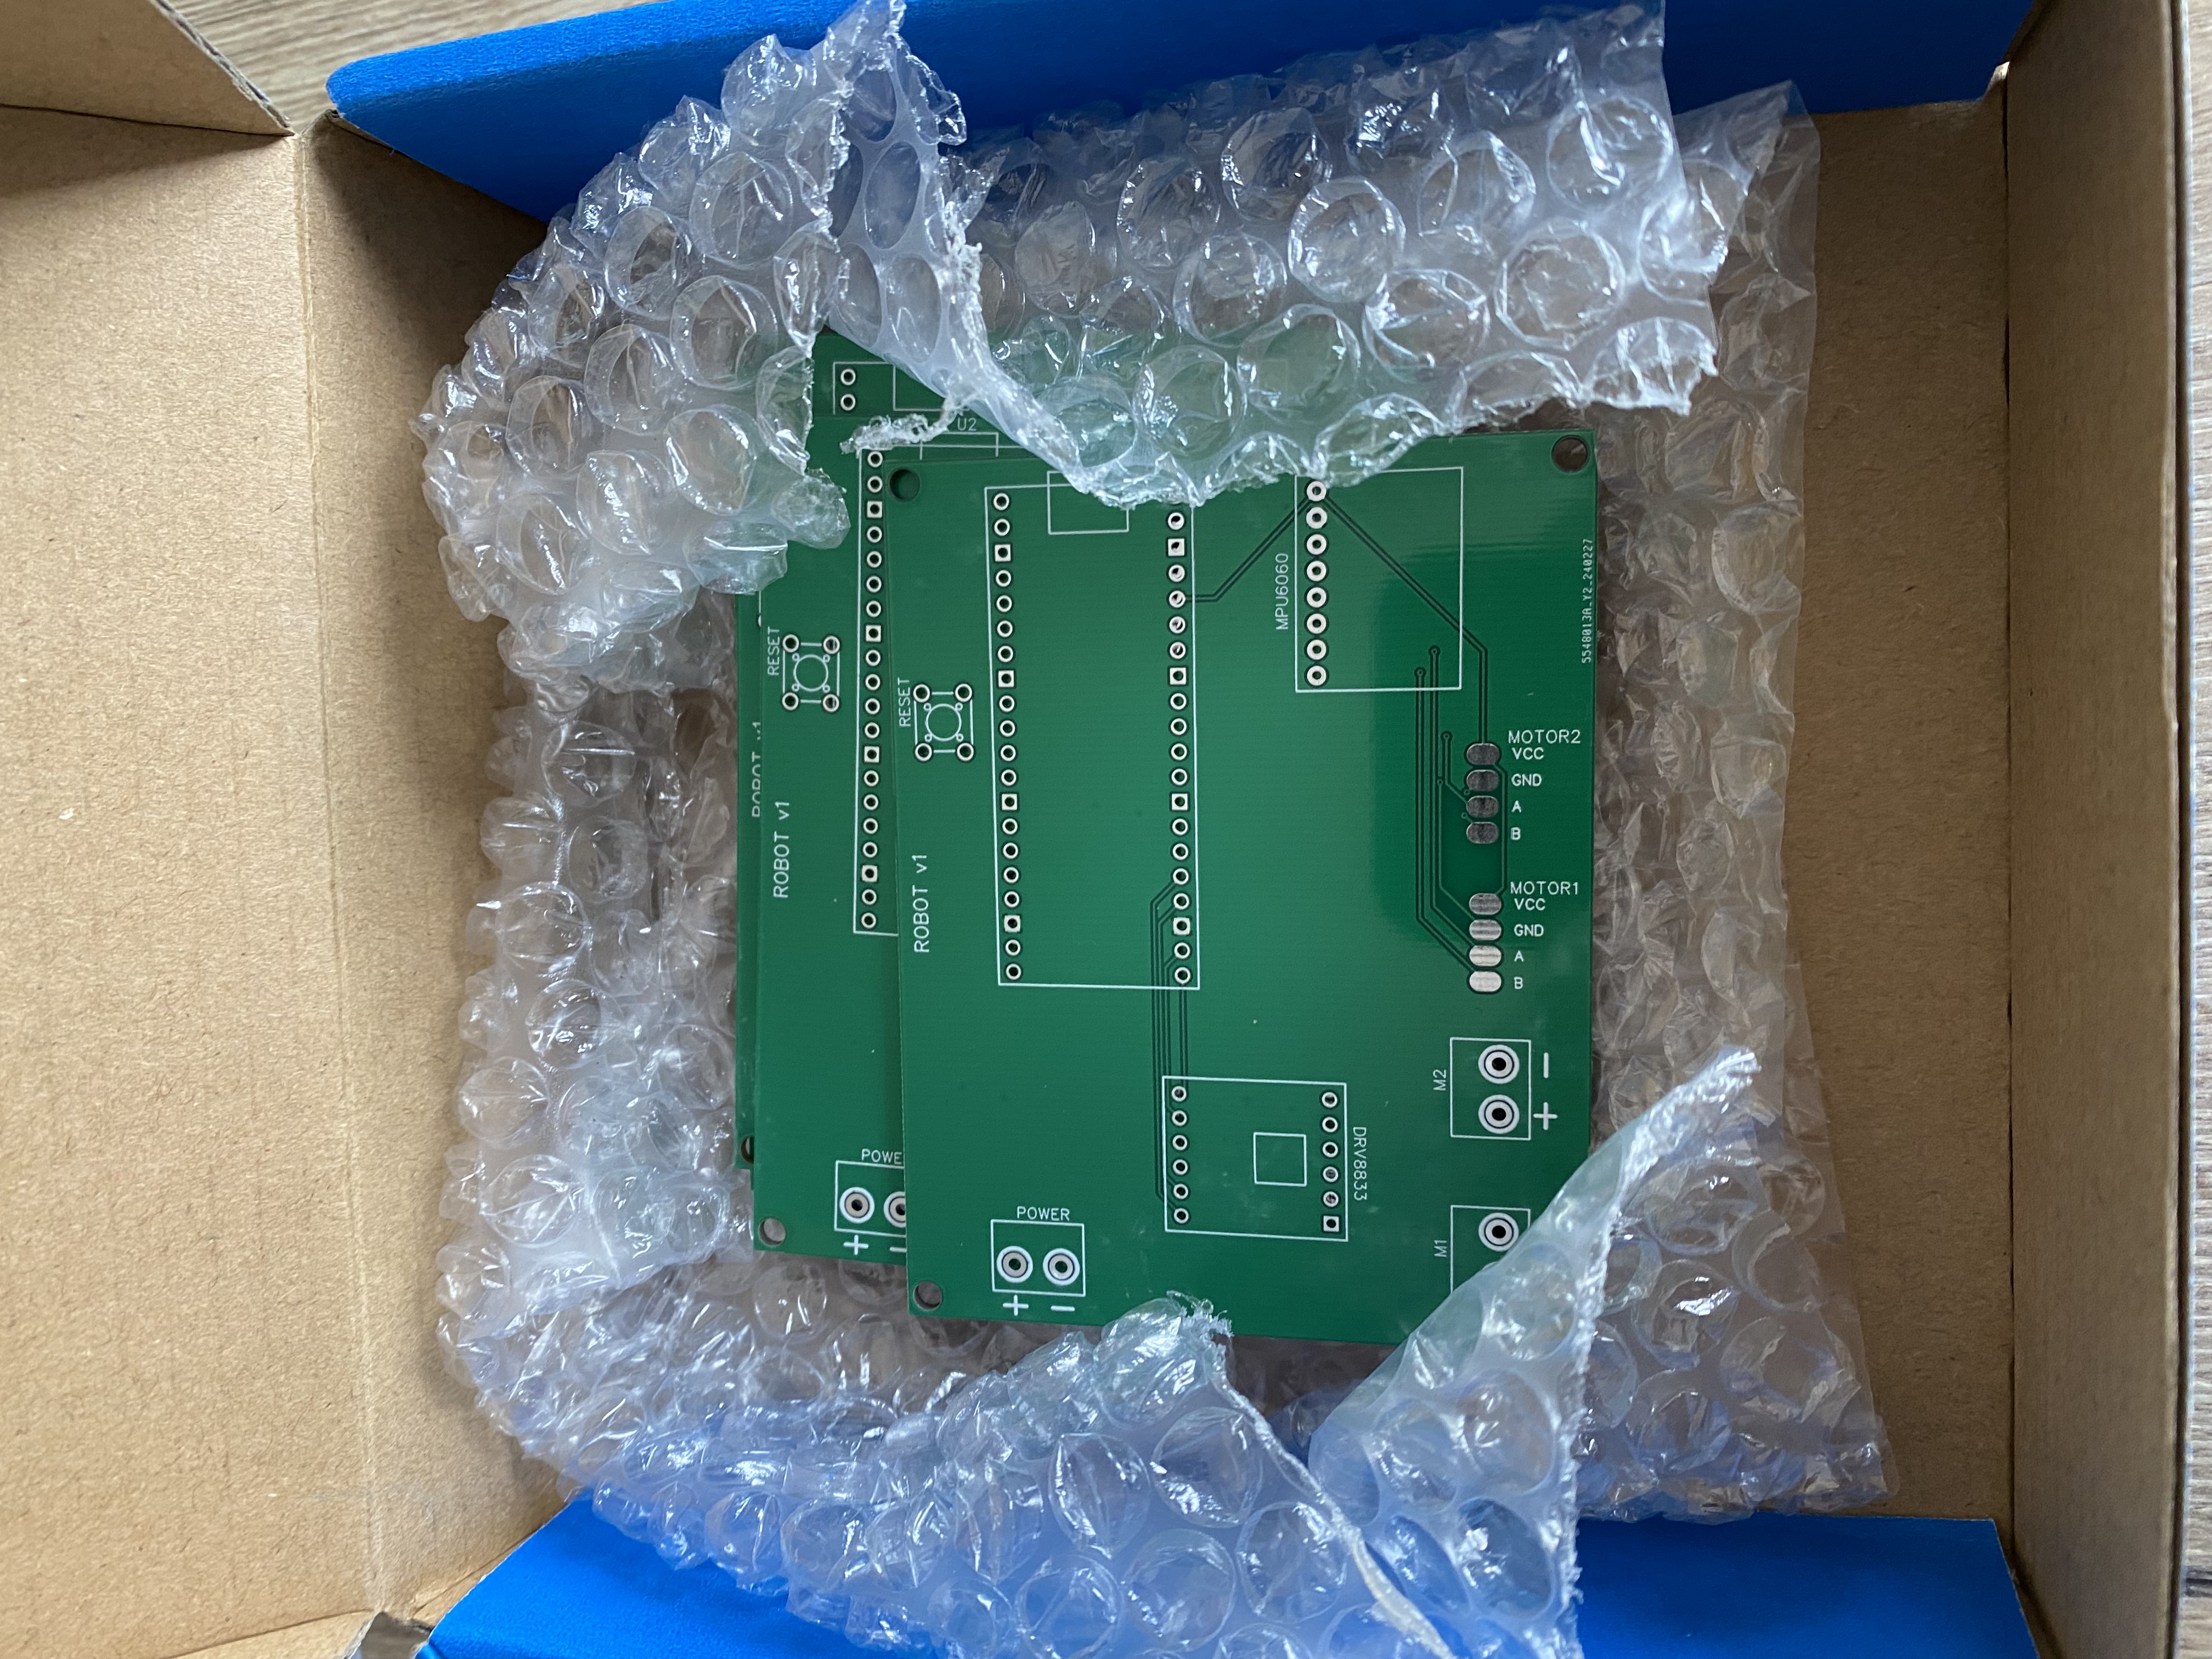
- MCU: Raspberry Pi Pico W
- IMU: MPU 6050
- Motor driver: DRV8833
- Code: Micropython